Lenses for Embedded Vision: Matching the Sensor, Mount, and Camera Assembly
Choose the lens against the camera board and the image it must produce. The processor name does not specify the optics.

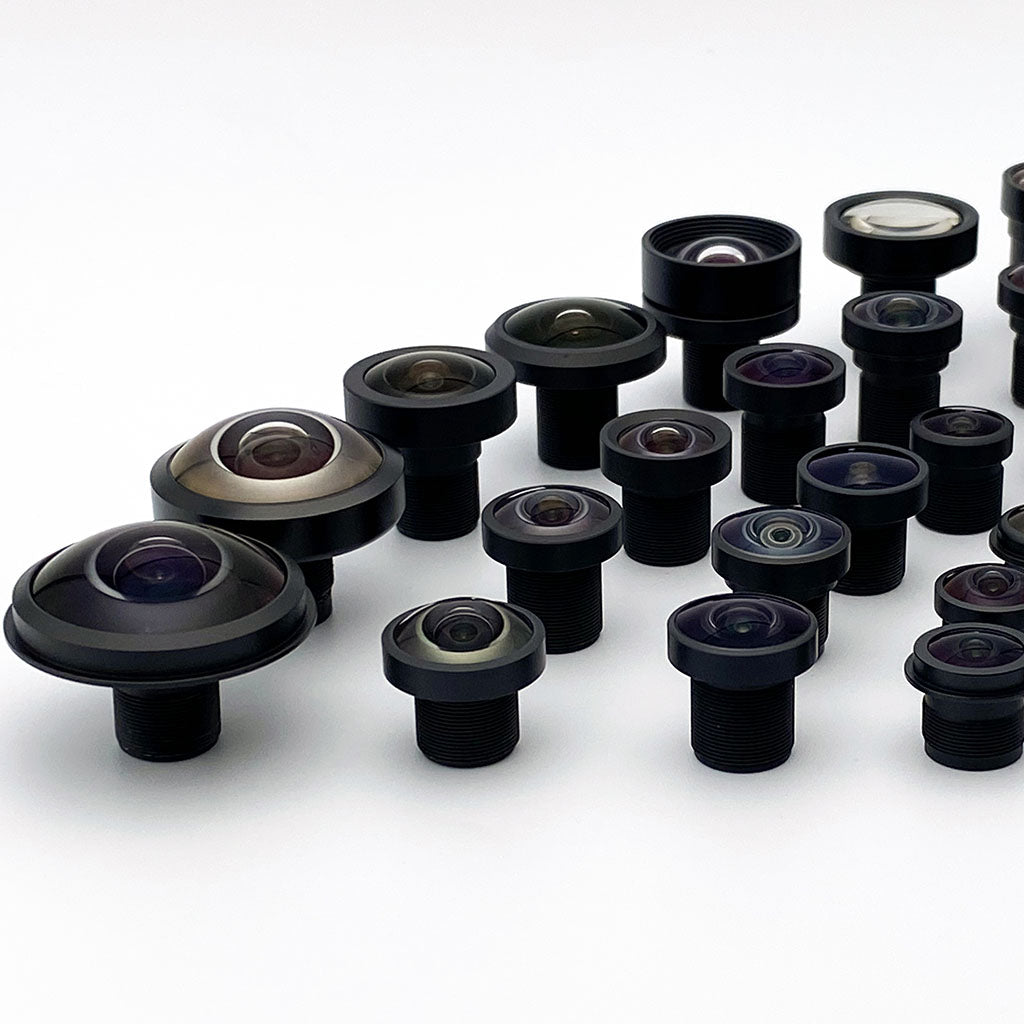
Lens selection for embedded vision starts with the sensor’s active area, the required field of view, and the available mechanical space. An M12 thread confirms one part of the fit. You still need enough focus travel, clearance behind the lens, and acceptable image quality across the sensor in the finished camera.
Choose the Mount and Check the Fit
An embedded camera combines a lens, holder, sensor board, and host processor. The lens mount defines part of the mechanical interface. It does not guarantee focus, sensor coverage, or image quality.
| マウント | インターフェース | Check |
|---|---|---|
| M12 / Sマウント | M12×0.5 thread; no common flange focal distance | Holder height, focus travel, and rear clearance. |
| Cマウント | 1-inch, 32-thread-per-inch thread; 17.526mm flange focal distance | Lens size, focus range, and iris access. |
| CSマウント | Same thread as C-mount; 12.526mm flange focal distance | A C-mount lens needs a 5mm spacer on a CS-mount camera, subject to clearance. |
Many M12 assemblies focus by turning the complete lens in the holder. An adjustable iris is useful when lighting can support a smaller aperture. Compare the actual lens drawings and mechanisms rather than assuming every lens with the same mount behaves alike.

Match Sensor Coverage and Detail
Use the sensor's active width, height, and diagonal in millimeters. Nominal inch-format names are historical labels, not physical dimensions. The lens must cover the area you use with enough brightness and contrast, including the corners.
The modulation transfer function (MTF) describes contrast transfer at different spatial frequencies. Pixel pitch p sets the row or column sampling Nyquist frequency, 1/(2p). For 1.55μm pixels, that is about 323 line pairs per millimeter at the sensor. Color-filter patterns and processing also affect the camera's response.
Pixel pitch is a necessary reference, but there is no universal acceptable MTF value at Nyquist. Choose “good enough” from the features your application must detect and test across the required image area. The MTF guide explains the plots and sampling limits.
Use the field-of-view calculator to estimate focal length. At short distances, use a finite-distance model and the lens's stated distance reference. For wide-angle and fisheye lenses, check the actual projection and image coverage.
Check Chief Ray Angle
Chief ray angle (CRA) is the angle at which the ray through the center of the aperture stop reaches the sensor, measured from the sensor normal. In plain terms, it describes how obliquely the center of each ray bundle arrives. Sensor microlenses are designed for a particular range of these angles.
A mismatch can reduce corner brightness or change color shading. Match the lens profile to the sensor maker's guidance, such as ST's VD55G1 datasheet. The aperture and the rest of the ray bundle matter too.
Calibration can correct repeatable shading, as the onsemi AR0542 documentation describes. It cannot replace lost photons, and correction gains amplify noise. Check corner signal-to-noise ratio after correction.
Check the Camera Board and Optical Stack
The camera board determines lens compatibility. A Jetson or Raspberry Pi host does not define the mount, and a MIPI CSI-2 connection alone does not establish driver support.
Raspberry Pi's documentation distinguishes the fixed-focus Camera Module 2 from the autofocus Camera Module 3. The High Quality Camera has C/CS-mount and M12 versions. Check the board version before ordering optics.
Include the sensor cover glass, filters, and any protective window in the optical design. Glass near the sensor can change focus and aberrations. Lens back focal length, measured from the rear optical surface to the image plane for an object at infinity, is not the holder height.
Leave room to focus and lock the lens without touching the sensor stack. Recheck focus after locking and at operating temperature.

Let the Application Set the Tradeoffs
A wider field keeps more of the scene visible, but distributes the sensor's samples over a larger angle. Check whether the smallest required feature still occupies enough pixels and retains enough contrast.
Fisheye lenses can support simultaneous localization and mapping (SLAM) when the software uses a suitable calibration model. OpenCV's fisheye model is one example. For stereo, calibrate each camera and their relative positions; buying lenses from one lot does not prove that they are matched.
For day/night imaging, make sure the filter arrangement passes the infrared illuminator's band. A lens corrected across visible and near-infrared wavelengths may share one focus setting; refocusing is another option. Test both illumination modes with the actual filters.
Compare Samples on the Same Camera
Test candidates on the same sensor board and save center and corner crops. Run the intended detection or measurement task, rather than judging a resolution label alone. This can reveal lower-cost lenses that still meet the requirement.
For a lens inquiry, send the sensor dimensions and pixel pitch, field of view, working-distance range, illumination band, and board drawing. Include operating temperatures and an example of the smallest feature the camera must distinguish.
よくある質問
Will any M12 lens work on an M12 camera board?
The thread may fit, but focus travel, rear clearance, image circle, and sensor-stack compatibility still need checking. Confirm the holder height against the lens drawing, then measure image quality on the assembled board.
Do Jetson and Raspberry Pi use the same lens mount?
The camera board determines the mount. The processor and MIPI CSI-2 interface do not define it. Raspberry Pi offers integrated-optics cameras and interchangeable-lens cameras, while Jetson-compatible camera boards vary by supplier.
Does lens MTF need to exceed a fixed value at Nyquist?
No universal value applies. Nyquist describes sensor sampling. The required contrast transfer depends on the feature, its contrast, noise, and the processing pipeline. Establish an acceptance criterion from the imaging task and verify it across the required field.
Can software correct CRA mismatch?
Shading calibration can correct repeatable brightness and color variation within the pipeline’s range. It cannot recover lost photon signal, and correction gains amplify noise. Verify corner signal-to-noise ratio and color uniformity under the operating illumination.
References
- Rudolf Kingslake and R. Barry Johnson, Lens Design Fundamentals, 2nd ed. (2010). Academic Press. Chapter 3 covers paraxial rays and first-order optics; §1.1.5 discusses manufacturing tolerances.
- STMicroelectronics, VD55G1 Datasheet, DS13604. The “Microlenses and CRA matching” section gives a sensor-specific profile and lens-selection tolerance.
- onsemi, AR0542 Datasheet. Pages 3 and 22 describe color/brightness shading correction, including compensation for CRA mismatch.
- Raspberry Pi Camera Documentation. Official camera models, focus mechanisms, and interchangeable-lens mount options.
- OpenCV Fisheye Camera Model. Projection, calibration, and stereo-rectification interfaces for fisheye cameras.
Talk With Commonlands Engineering
Send the camera-board drawing and imaging requirements with your lens inquiry. Include the cover glass and filters so we can check the optical stack as well as the thread.